Wind direction vane + turbine yaw control
The other half of the college wind turbine idea. It reads where the wind is coming from and turns the turbine to face it. On small turbines a tail fin does this. Bigger machines, or a turbine you want to turn out of a storm on purpose, need a motorised yaw drive, and this is its controller.
Reading the wind direction
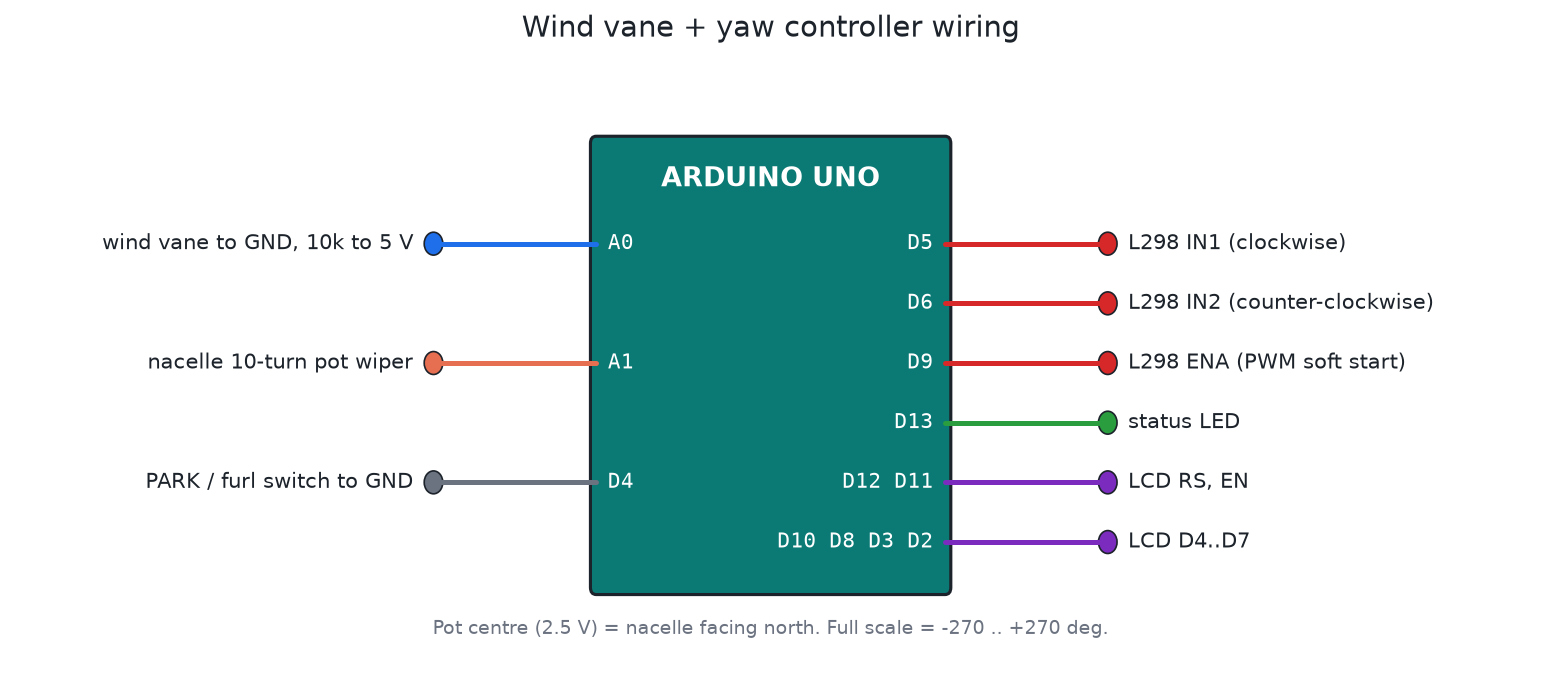
The vane is the common 16-position resistor type (the SparkFun / Argent weather meter vane). Each direction connects a different resistor, so with a 10k pull-up every direction gives its own voltage on A0. The firmware works out the 16 expected ADC values from the resistor list and picks the nearest. A reading far from all 16 means a broken or shorted vane, and it's ignored.
Not chasing every gust
Wind direction swings around all the time. If the turbine followed every swing, the yaw motor would wear out in weeks. So:
- Direction is a vector average over about 30 s. Angles can't be averaged as plain numbers: 350° and 10° average to 0° (north), not 180°.
- If the wind is too changeable (the averaged vector is short), it doesn't yaw at all.
- It only starts turning when the error has stayed above 15° for 10 s, and it stops within 5° of the target.
- The motor ramps up over about 1 s (soft start on the ENABLE pin) to go easy on the gearbox.
Cable twist protection
The power cable runs down the tower, so the nacelle can't spin round forever. Here it may turn between −270° and +270° (one and a half turns each way). For every new wind direction, the controller looks at all the equal angles (for example 300° is also −60°), keeps the ones inside the limit, and picks the closest. Sometimes that means going the long way round, which also untwists the cable. The test runs a sequence of wind changes that would wind the cable up and checks it never goes past ±270°.
Other features
- PARK / furl switch: turns the rotor 90° out of the wind, for storms or working on the turbine.
- YAW STUCK: if the target isn't reached within 90 s (jammed gear, dead motor, broken pot), the motor stops and the fault is latched.
- LCD shows the wind direction (N, NNE, ...), the nacelle angle and the mode. A CSV log goes out over USB.
Files
| File | What it is |
|---|---|
firmware/wind_vane_yaw/wind_vane_yaw.ino | Firmware |
firmware/build/wind_vane_yaw.hex | Real-time build |
firmware/build/wind_vane_yaw_sim_x10.hex | Averaging and start delay 10x faster, for Proteus |
test/sim_test.c | Simulator test, with a simulated nacelle that turns when the motor runs |
Building it in Proteus
- Add
ARDUINO UNO,LM016L,L298(orL293D),MOTOR-DC,SW-SPSTfor PARK, and twoPOT-HG. One stands in for the vane (or use aRESper direction and a rotary switch), the other for the nacelle position. - Wire it as in
images/wiring.png. Set the Arduino's Program File tofirmware/build/wind_vane_yaw_sim_x10.hex. - Run it. Change the vane pot and watch the motor turn after the delay. Turn the nacelle pot by hand to "follow" the motor (or couple a second pot to the motor in your head), and see it stop when it's on target.
Save it as proteus/wind-vane-yaw.pdsprj and commit it.
In the field
Use a 10-turn pot geared to the yaw ring, or better, an absolute magnetic encoder (AS5600 type) with a turns counter. Add limit switches at ±280° that cut the motor in hardware, as a backup for the software limit.